Autonomous systems
Robots and vehicles get model updates in the field, often from a supplier.
Intended, not deployed
Intended application areas. Vraelis has no customer deployments in them.
Models ship to machines in the field.
Updates land in someone else's fleet
In a facility or fleet the supplier does not operate.
An unexpected release is a security and operational risk
A different release, or the wrong machine, changes what it does.
The first question is which model
When a machine surprises you, the answer should come from a record.
Hypothesis
Robotics is one segment we study. Release and platform engineers at robotics suppliers and integrators meet this problem early.
The workflow, in this area
- Identify the release.
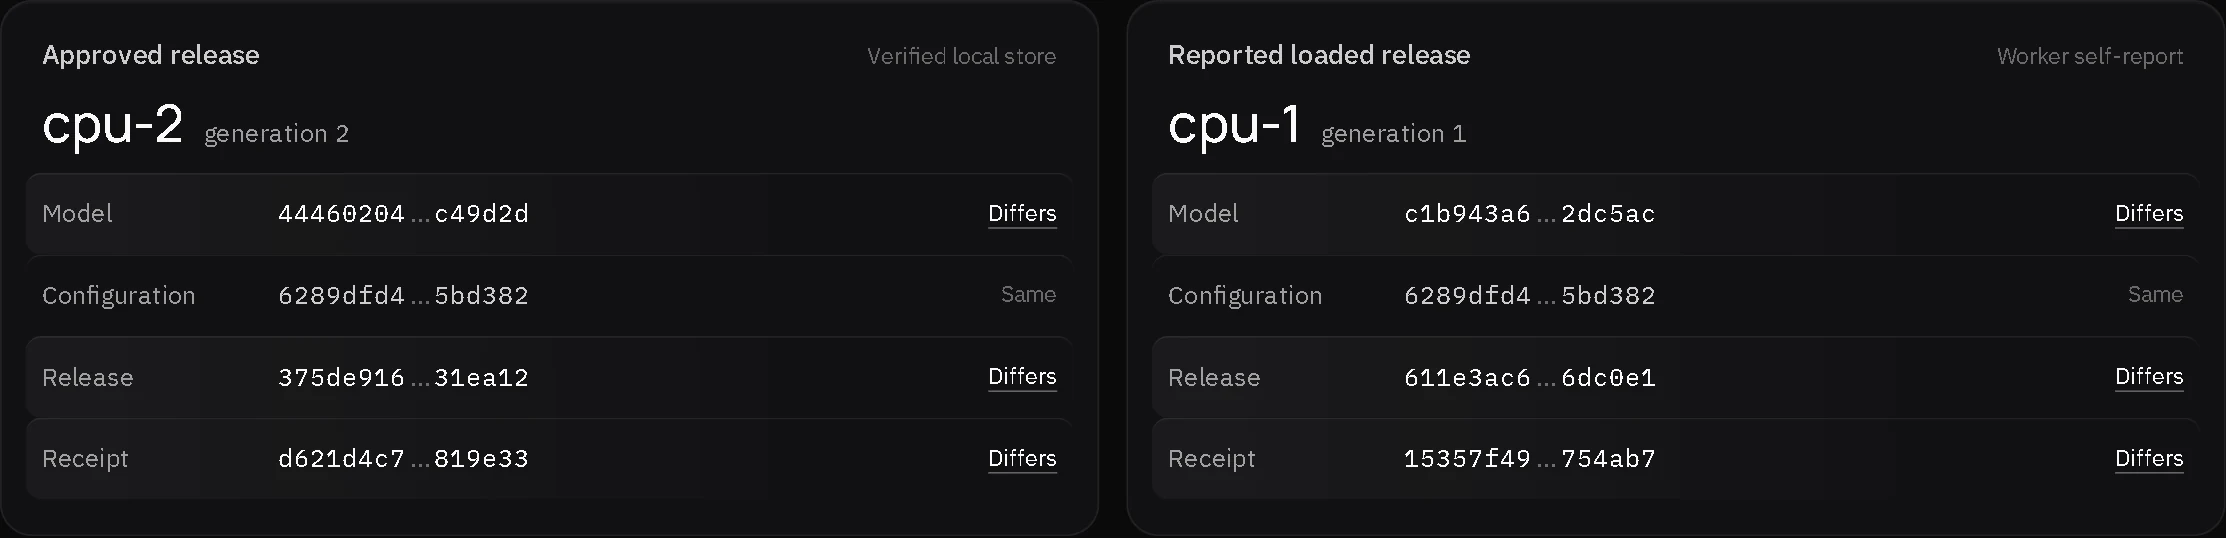
- Bind approval to the release and destination. Destination-bound approval: one machine's approval does not cover another.
- Integrate with a supported runtime.
- Compare approved and reported. A version mismatch shows as reload pending, not assumed.
- Preserve discrepancies, missing evidence and recovery.
Not claimed
- No deployments on robots or vehicles, and no customers.
- No robot or vehicle integration. The experiment is a synthetic ONNX CPU workload.
- No protection against adversarial inputs or perception attacks.
- No certification, and no evidence freshness for machines in the field: heartbeats are not built.
- No hardware attestation. Runtime identity is a worker self-report.
Last updated: October 12, 2026